
Home/Products/Hydraulics/A6VE series/A6VE series
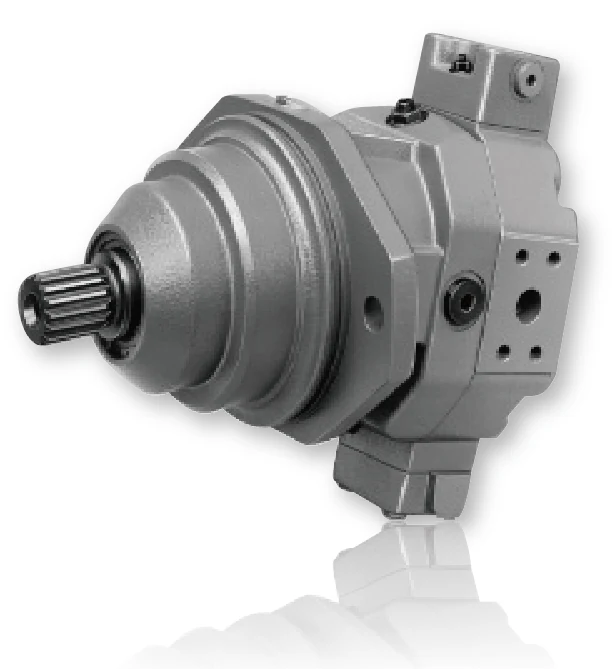
A6VE series
A6VE series
Variable motor with the planetary gearbox built in, inserted as one unit into the track frame or hub. Travel drive on rigs and excavators, without a separate gearbox or shaft.
Features
- Variable plug-in motor with swash-plate type axial tapered-piston rotor group, for hydrostatic drives in open and closed circuits
- Integrated into mechanical gearboxes thanks to the recessed mounting flange at the centre of the housing (a very space-saving design)
- Easy to install — simply plug into the mechanical gearbox (no configuration instructions to follow)
- Test unit ready for installation
- Especially for mobile machinery applications
- Displacement is infinitely variable between Vg max and Vg min = 0
- The wide control range lets the motor meet high speed and high torque requirements
- Output speed depends on pump flow and motor displacement
- Output torque increases with the differential pressure between high and low pressure sides and with displacement
Technical data
| Size | 28 | 55 | 80 | 107 | 160 | 250 |
|---|---|---|---|---|---|---|
| Geometric displacement · Vg maxcm³ | 28.1 | 54.8 | 80 | 107 | 160 | 250 |
| Geometric displacement · Vg mincm³ | 0 | 0 | 0 | 0 | 0 | 0 |
| Geometric displacement · Vg xcm³ | 18 | 35 | 51 | 68 | 61 | 188 |
| Max. speed · at Vg maxn nom · rpm | 5550 | 4450 | 3900 | 3550 | 3100 | 2700 |
| Max. speed · Vg < Vg xn max · rpm | 8750 | 7000 | 6150 | 5600 | 4900 | 3600 |
| Max. speed · Vg = 0n max · rpm | 10450 | 8350 | 7350 | 6300 | 5500 | 3600 |
| Input flow · n nom and Vg maxqV max · l/min | 156 | 244 | 312 | 380 | 496 | 675 |
| Torque · Vg max, Δp = 400 barT · Nm | 179 | 349 | 509 | 681 | 1019 | – |
| Torque · Vg max, Δp = 350 barT · Nm | 157 | 305 | 446 | 596 | 891 | 1391 |
| Torsional stiffness · C minkNm/rad | 6 | 10 | 16 | 21 | 35 | 60 |
| Torsional stiffness · C maxkNm/rad | 18 | 32 | 48 | 65 | 105 | 181 |
| Moment of inertia of rotating groupJ · kgm² | 0.0014 | 0.0042 | 0.008 | 0.0127 | 0.0253 | 0.061 |
| Max. angular accelerationα · rad/s² | 47000 | 31500 | 24000 | 19000 | 11000 | 10000 |
| Housing volumeV · L | 0.5 | 0.75 | 1.2 | 1.5 | 2.4 | 3.0 |
| Weight · port plate 02 / 37 / 38m · kg | 16 | 26 | 34 | 47 | 64 | 90 |
| Weight · port plate 22m · kg | – | 35 | 43 | 53 | 72 | – |
Data table: theoretical values, excluding coefficients and tolerances; approximate. ① Geometric displacement. ② With observance of maximum permissible input flow. ③ Input flow = geometric displacement × speed. ④ Torque without efficiency losses.