
Home/Products/Hydraulics/A6VM series 65/A6VM series 65
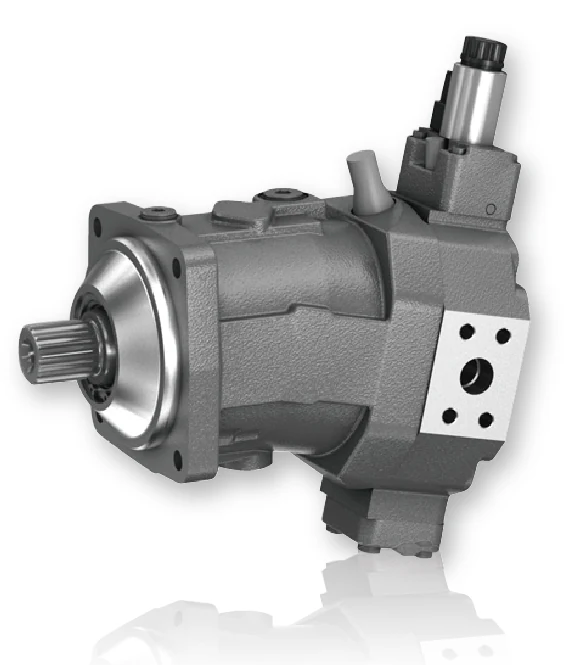
A6VM series 65
A6VM series 65
The series 65 bent-axis variable motor, supplied alongside series 63 with its own mounting and control interfaces. Closed circuit travel drives, replaced against the original build.
Features
- Variable motor with swash-plate type axial tapered-piston rotor group, for hydrostatic drives in open and closed circuits
- For mobile machinery and stationary applications
- The wide control range lets the motor meet high speed and high torque requirements
- Displacement is infinitely variable between Vg max and Vg min = 0
- Output speed depends on pump flow and motor displacement
- Output torque increases with the differential pressure between high and low pressure sides and with displacement
- Hydrostatic transmission over a wide control range
- A choice of control devices is available
- Cost saving through eliminating the gearbox and using a smaller pump — compact, robust motor with a long service life
- High power density
- Good starting characteristics
- Models with 9-piston rotating group
- Good low-speed characteristics
- High consistency
Technical data
| Size | 28 | 55 | 80 | 107 | 140 | 160 | 200 | 250 | 355 | 500 | 1000 |
|---|---|---|---|---|---|---|---|---|---|---|---|
| Geometric displacement ① · Vg maxcm³ | 28.1 | 54.8 | 80 | 107 | 140 | 160 | 200 | 250 | 355 | 500 | 1000 |
| Geometric displacement · Vg mincm³ | 0 | 0 | 0 | 0 | 0 | 0 | 0 | 0 | 0 | 0 | 0 |
| Geometric displacement · Vg xcm³ | 18 | 35 | 51 | 68 | 88 | 61 | 76 | 188 | 270 | 377 | 762 |
| Max. speed ② · at Vg maxn nom · rpm | 5550 | 4450 | 3900 | 3550 | 3250 | 3100 | 2900 | 2700 | 2240 | 2000 | 1600 |
| Max. speed · Vg ≤ Vg xn max · rpm | 8750 | 7000 | 6150 | 5600 | 5150 | 4900 | 4600 | 3600 | 2950 | 2650 | 1600 |
| Max. speed · Vg = 0n max · rpm | 10450 | 8350 | 7350 | 6300 | 5750 | 5500 | 5100 | 3600 | 2950 | 2650 | 1600 |
| Input flow ③ · n nom and Vg maxqV max · l/min | 156 | 244 | 312 | 380 | 455 | 496 | 580 | 675 | 795 | 1000 | 1600 |
| Torque ④ · Vg max at Δp = 400 barT · Nm | 179 | 349 | 509 | 681 | 891 | 1019 | 1273 | – | – | – | – |
| Torque · Vg max at Δp = 350 barT · Nm | 157 | 305 | 446 | 596 | 778 | 891 | 1114 | 1391 | 1978 | 2785 | 5571 |
| Torsional stiffness · Vg max to Vg/2c min · kNm/rad | 6 | 10 | 16 | 21 | 34 | 35 | 44 | 60 | 75 | 115 | 281 |
| Torsional stiffness · Vg/2 to 0 (interpolated)c max · kNm/rad | 18 | 32 | 48 | 65 | 93 | 105 | 130 | 181 | 262 | 391 | 820 |
| Moment of inertia of rotating groupJGR · kgm² | 0.0014 | 0.0042 | 0.008 | 0.0127 | 0.0207 | 0.0253 | 0.0353 | 0.061 | 0.102 | 0.178 | 0.55 |
| Max. angular accelerationα · rad/s² | 47000 | 31500 | 24000 | 19000 | 11000 | 11000 | 11000 | 10000 | 8300 | 5500 | 4000 |
| Housing volumeV · L | 0.5 | 0.75 | 1.2 | 1.5 | 1.8 | 2.4 | 2.7 | 3.0 | 5.0 | 7.0 | 16.0 |
| Weight (approx.)m · kg | 16 | 26 | 34 | 47 | 60 | 64 | 80 | 100 | 170 | 210 | 430 |
Data table: theoretical values, excluding coefficients and tolerances; approximate. ① Geometric displacement per revolution. ② With observance of maximum permissible input flow. ③ Input flow = geometric displacement × speed. ④ Torque without efficiency losses.