
Home/Products/Hydraulics/A6VM series 63
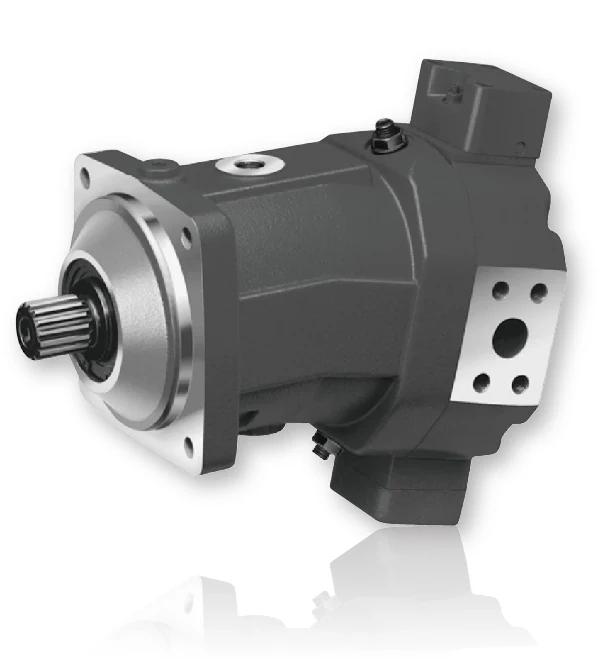
A6VM series 63
A6VM series 63
Bent-axis variable motor, series 63, displacement stepless from zero to maximum with high torque at low speed. Travel drive motor, also used for swing and winch, with HD, EP or DA control.
Features
- Variable motor with swash-plate type axial tapered-piston rotor group, for hydrostatic drives in open and closed circuits
- For mobile machinery and stationary applications
- The wide control range lets the motor meet high speed and high torque requirements
- Displacement is infinitely variable between Vg max and Vg min = 0; output speed depends on pump flow and motor displacement
- Output torque increases with the differential pressure between high and low pressure sides and with displacement
- Hydrostatic transmission over a wide control range, with a choice of control devices
- Cost saving through eliminating the gearbox and using a smaller pump; compact, robust motor with a long service life
- High power density
- Good starting characteristics
- Low swivelling torque
Technical data
| Size | 28 | 55 | 80 | 107 | 140 | 160 | 200 | 250 | 355 | 500 | 1000 |
|---|---|---|---|---|---|---|---|---|---|---|---|
| Geometric displacement · Vg maxcm³ | 28.1 | 54.8 | 80 | 107 | 140 | 160 | 200 | 250 | 355 | 500 | 1000 |
| Geometric displacement · Vg mincm³ | 0 | 0 | 0 | 0 | 0 | 0 | 0 | 0 | 0 | 0 | 0 |
| Geometric displacement · Vg xcm³ | 18 | 35 | 51 | 68 | 88 | 61 | 76 | 188 | 270 | 377 | 762 |
| Max. speed · at Vg maxn nom · rpm | 5550 | 4450 | 3900 | 3550 | 3250 | 3100 | 2900 | 2700 | 2240 | 2000 | 1600 |
| Max. speed · Vg < Vg xn max · rpm | 8750 | 7000 | 6150 | 5600 | 5150 | 4900 | 4600 | 3600 | 2950 | 2650 | 1600 |
| Max. speed · Vg = 0n max · rpm | 10450 | 8350 | 7350 | 6300 | 5750 | 5500 | 5100 | 3600 | 2950 | 2650 | 1600 |
| Input flow · n nom and Vg maxqV max · l/min | 156 | 244 | 312 | 380 | 455 | 496 | 580 | 675 | 795 | 1000 | 1600 |
| Torque · Vg max, Δp = 400 barT · Nm | 179 | 349 | 509 | 681 | 891 | 1019 | 1273 | – | – | – | – |
| Torque · Vg max, Δp = 350 barT · Nm | 157 | 305 | 446 | 596 | 778 | 891 | 1114 | 1391 | 1978 | 2785 | 5571 |
| Torsional stiffness · C minkNm/rad | 6 | 10 | 16 | 21 | 34 | 35 | 44 | 60 | 75 | 115 | 281 |
| Torsional stiffness · C maxkNm/rad | 18 | 32 | 48 | 65 | 93 | 105 | 130 | 181 | 262 | 391 | 820 |
| Moment of inertia of rotating groupJ · kgm² | 0.0014 | 0.0042 | 0.008 | 0.0127 | 0.0207 | 0.0253 | 0.0353 | 0.061 | 0.102 | 0.178 | 0.55 |
| Max. angular accelerationα · rad/s² | 47000 | 31500 | 24000 | 19000 | 11000 | 11000 | 11000 | 10000 | 8300 | 5500 | 4000 |
| Housing volumeV · L | 0.5 | 0.75 | 1.2 | 1.5 | 1.8 | 2.4 | 2.7 | 3.0 | 5.0 | 7.0 | 16.0 |
| Weight (approx.)m · kg | 16 | 26 | 34 | 47 | 60 | 64 | 80 | 100 | 170 | 210 | 430 |
Data table: theoretical values, excluding coefficients and tolerances; approximate. ① Geometric displacement. ② With observance of maximum permissible input flow. ③ Input flow = geometric displacement × speed. ④ Torque without efficiency losses.